< Computational Applications on GitHub >
Coordinated Underwater Inspection
We develop compact autonomous underwater vehicles and learning-based control for coordinated inspection of submerged structures. Our goal is to improve visual inspection of bridge foundations and other underwater infrastructure while reducing operator burden.
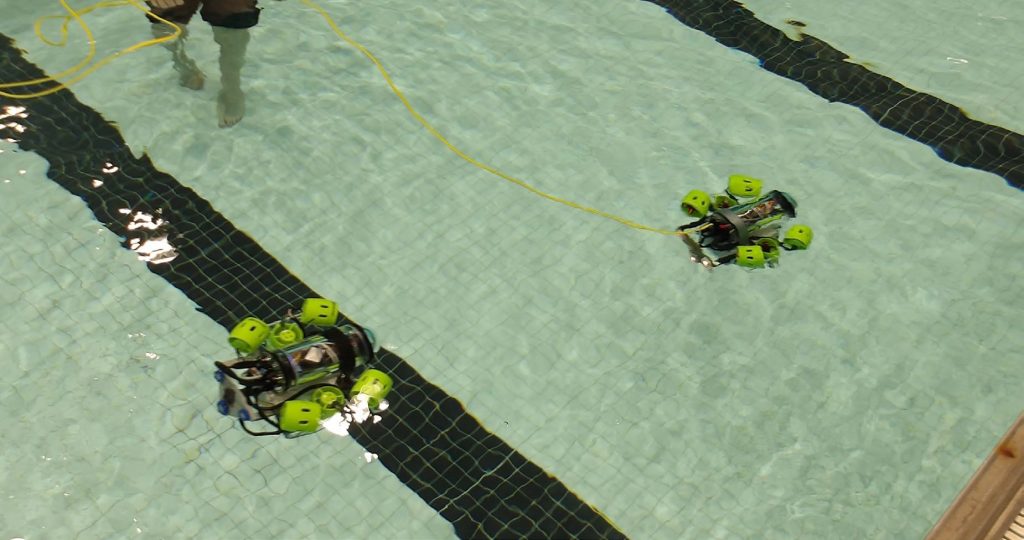
The six-thruster platform provides five degrees of freedom. Pool tests have demonstrated camera-based leader detection and following. Ongoing work expands multi-vehicle navigation and docking for power and data transfer. Proposed inspection tasks include detecting visible structural damage and erosion around foundations.
Vision-Based Navigation
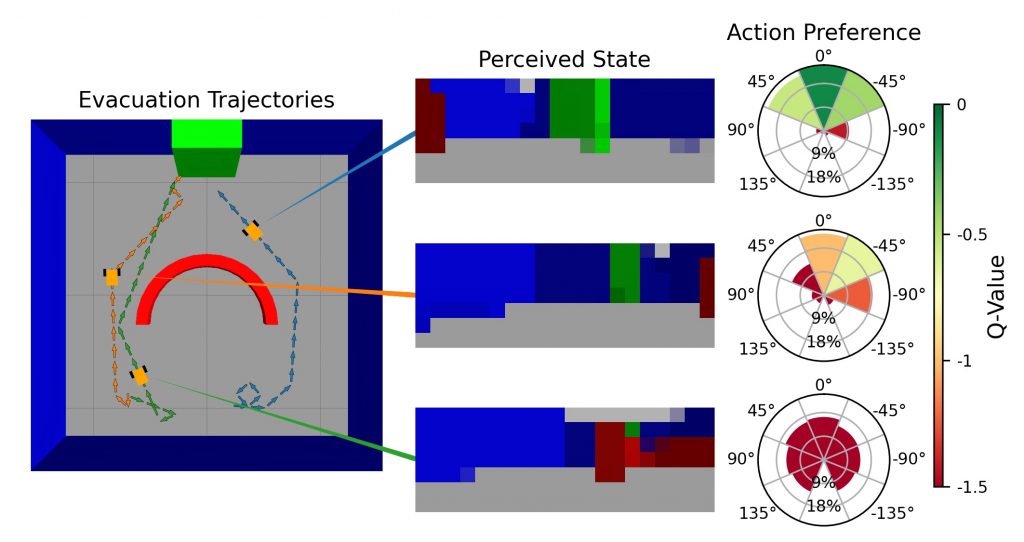
Our simulation research uses deep reinforcement learning to navigate from camera images without a pre-existing obstacle map. Deep Dyna-Q studies demonstrate goal-directed navigation around static, moving, and concave obstacles. These studies inform the development of mini-AUV autonomy, alongside separate underwater vehicle tests.